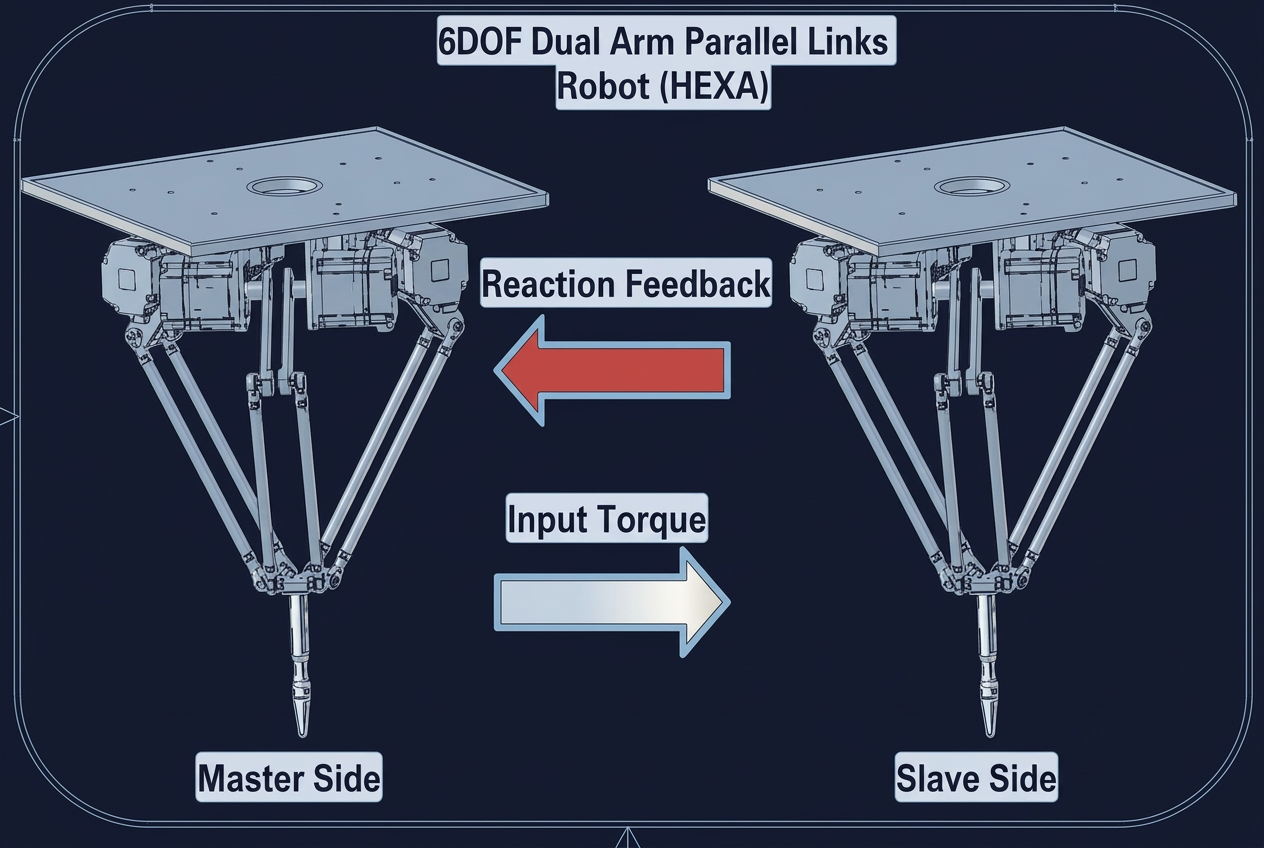
FIG. 01 · Ongoing · Yokohama, Japan
Real World Robotics
- Project type
- Robotics, Data-driven Control, Model-free Control
- Date
- October 2023 — Ongoing
- Location
- Yokohama, Japan
- Role
- Student Researcher
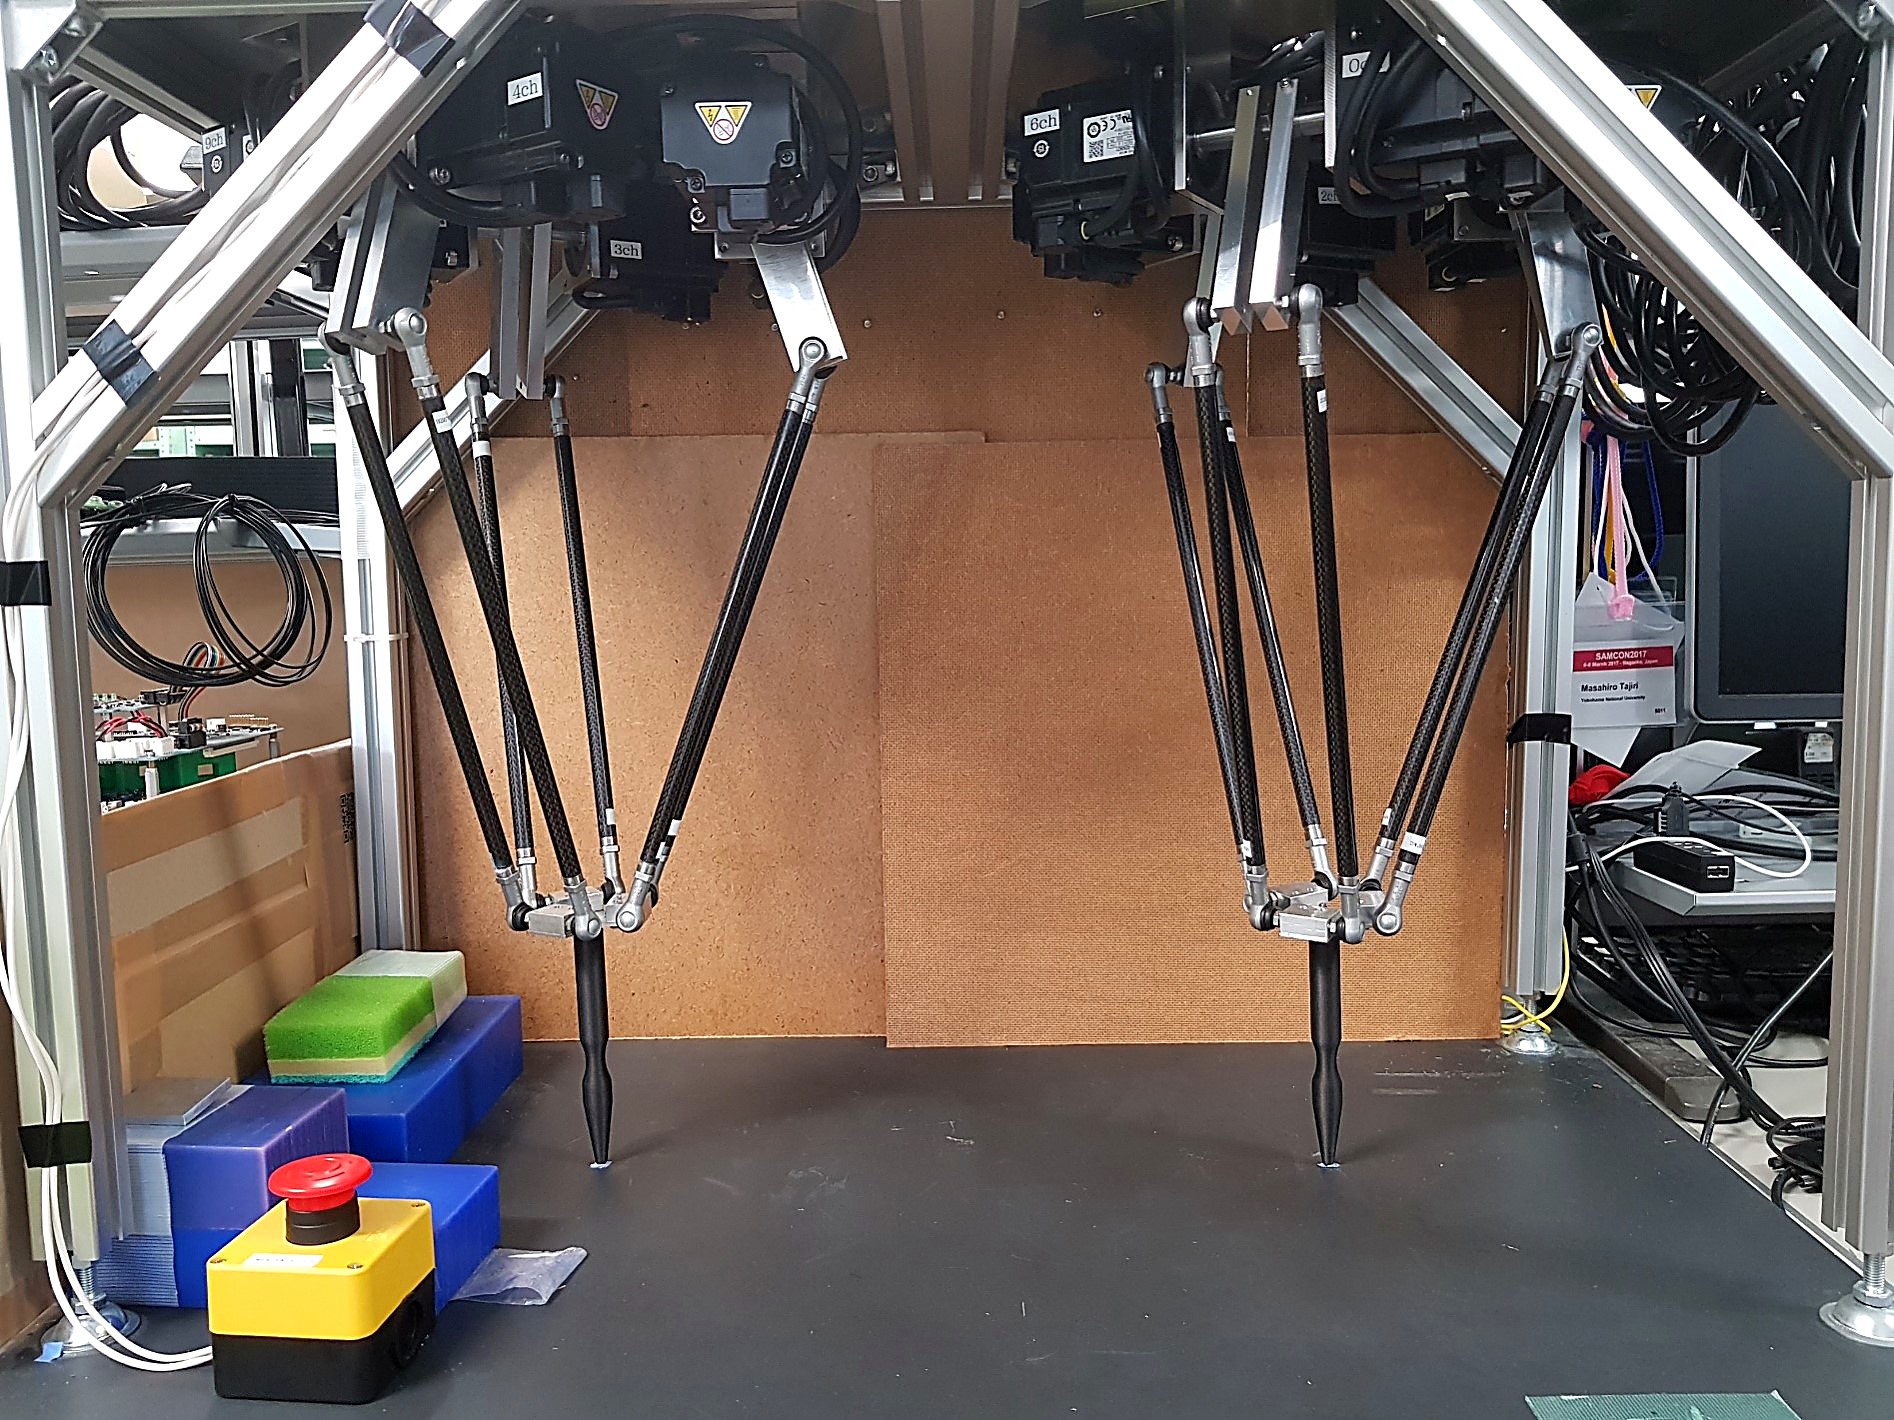
A study on the application of data-driven based methods in robotics. In this research, we are working in developing and using a novel data-driven control method to achieve the full controllability of a two-in-one 6DOF parallel robotic arm.
- Data-driven control
- Model-free
- 6DOF parallel arm